Teach robotsevery human skill.
The data engine for physical AI. Camera pose, hands and actions for every frame of first-person video.
#1 LaMAria mono-inertial · 750 hours open-sourced · 10,000+ hours of real-world data


Capture to training set.
Run the full pipeline or any single stage.╔═ FPV LABS DATA ENGINE ═════════════════════════════════════════════════════════════════════════════╗ ║ ║░ ║ ┏━━━━━━━━━━━━━━━━━┓ ┏━━━━━━━━━━━━━━━━━┓ ┏━━━━━━━━━━━━━━━━━┓ ┏━━━━━━━━━━━━━━━━━┓ ║░ ║ ┃ Capture ┃─────▶┃ FPV-SLAM ┃─────▶┃ Hands + Vidur ┃─────▶┃ Evaluate ┃──▶╫──▶ training set ║ ┃ Ego-OSCAR rig ┃ ┃ camera pose ┃ ┃ 21 joints x 2 ┃ ┃ score every ┃ ║░ ║ ┃ or Stera, iOS ┃ ┃ every frame ┃ ┃ timed actions ┃ ┃ session ┃ ║░ ║ ┗━━━━━━━━━━━━━━━━━┛ ┗━━━━━━━━━━━━━━━━━┛ ┗━━━━━━━━━━━━━━━━━┛ ┗━━━━━━━━━━━━━━━━━┛ ║░ ║ ║░ ╚════════════════════════════════════════════════════════════════════════════════════════════════════╝░ ░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░░
Benchmarks
LaMAria binocular-inertial · #3 · 77.3 short-walk score
iPhone pose vs 24-camera Vicon · drift under 1 cm
Research
All research →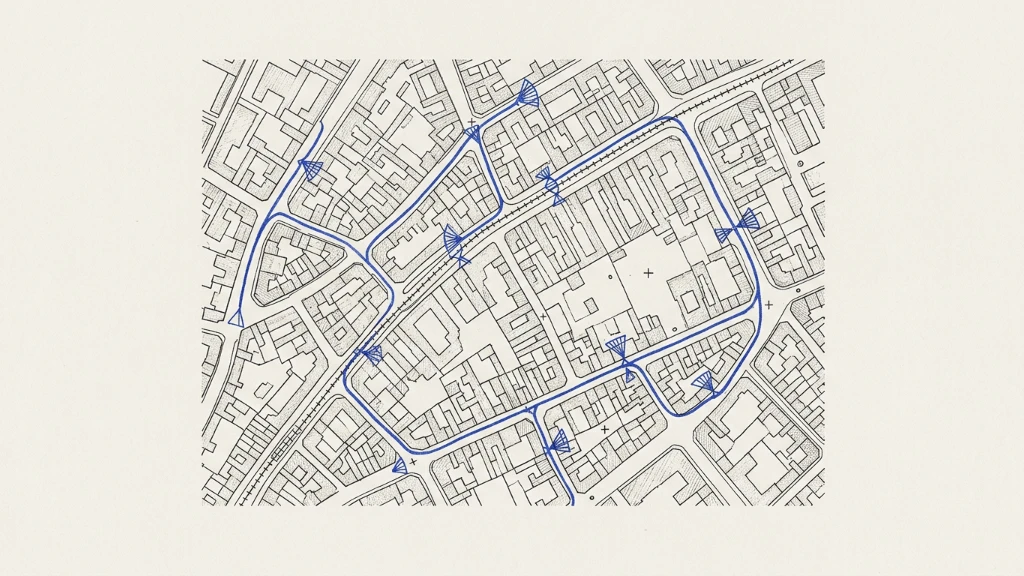 2026.10.30Introducing FPV-SLAM#1 on LaMAria mono-inertial. Leads all five categories.Read →
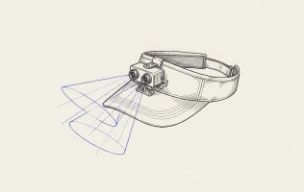 2026.08.14Introducing Ego-OSCARAn open stereo-inertial head rig, released with 550 hours of data.Read ↗
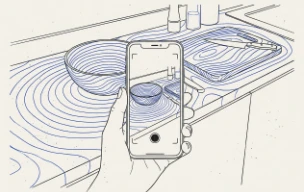 2026.07.28Stera 2.0 is open sourceThe whole RGB-D capture stack for phones: app, engine, backend.Read ↗
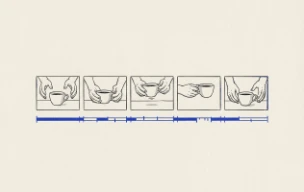 2026.07.21Introducing VidurAction labels for raw robot and human video. New state of the art on WGO-Bench.Read ↗